



-
Engineering student focused on robotics
Control, state estimation and embedded systems on real hardware · University of Trento, Italy
Autonomous drift parking
1:10 car · Feb–Oct 2026
The car finds a parking gap with its lidar and slides into it sideways: 47 cm for a 26 cm car. Nonlinear MPC (acados) at 50 Hz on a Raspberry Pi 4, vehicle model identified from IMU, encoders and overhead video (OpenCV marker tracking), EKF + AMCL localization on a lidar map, ESP32 + micro-ROS, same software in Gazebo.
Multi-process blockchain simulation
Team of 3 · Apr–Sep 2026
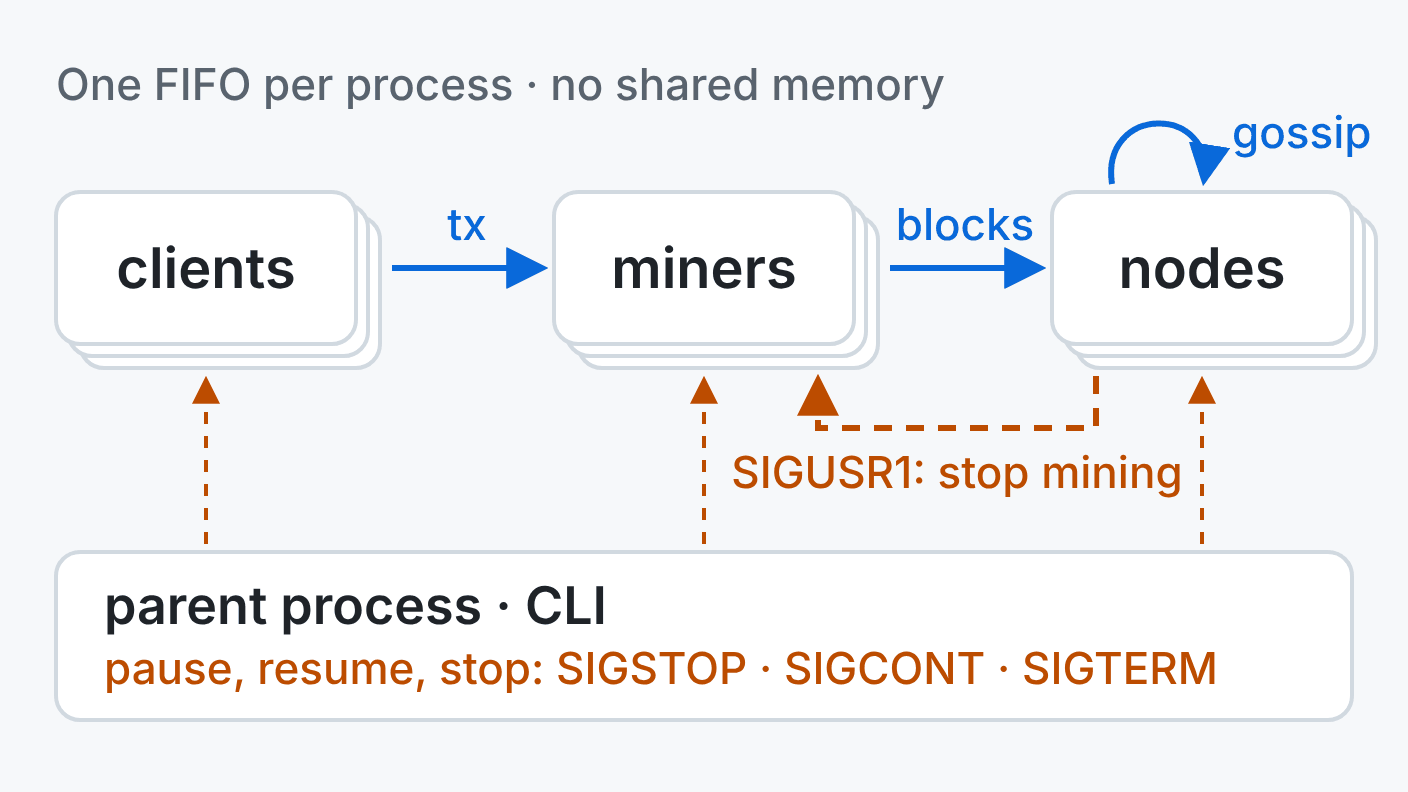
Nodes, miners and clients run as separate processes that share no memory: FIFOs for data, POSIX signals for control. Proof-of-work, Merkle trees and SHA-256 written from scratch; nodes reach consensus without a coordinator, and a Bash tool verifies the saved chain. Operating Systems course, graded 10/10.
Open source: small fixes merged in ros2/rclcpp (#3145) and ros2/rosbag2_bag_v2 (#52).
- SO-101 brick builder: a 3D-printed SO-101 arm that sorts toy bricks seen by a webcam and assembles them from a blueprint, with inverse kinematics and imitation learning (LeRobot).
- Pick-and-place with a UR5: Fundamentals of Robotics course project. Block detection and pose estimation, inverse kinematics and trajectories in simulation, then on the SO-101.
- Lidar SLAM car: Embedded Software for IoT team project on the drift car's chassis. It maps a room with its lidar, localizes itself (SLAM) and drives to a goal or along a path drawn on screen.
- University of Trento · 2024–2027
BSc in Computer, Communications and Electronic Engineering - Metalsistem S.p.A., Rovereto · Jun 2023
3D software developer intern: interactive 3D interface for industrial environments (Babylon.js, JavaScript) - ITT G. Marconi, Rovereto · 2019–2024
Diploma in Computer Science, Big Data track, 100/100
 Gelminaio
Follow




Pinned Loading
Something went wrong, please refresh the page to try again.
If the problem persists, check the GitHub status page or contact support.
If the problem persists, check the GitHub status page or contact support.